Open Robotics – Information architecture redesign
When did we work with Open Robotics?
2025 – Present
What did we do?
Information Design, Tools Consultancy, and Technical Authoring
Where can I find this documentation
Open Robotics documentation can be found here
Key stats
3di provided
300+
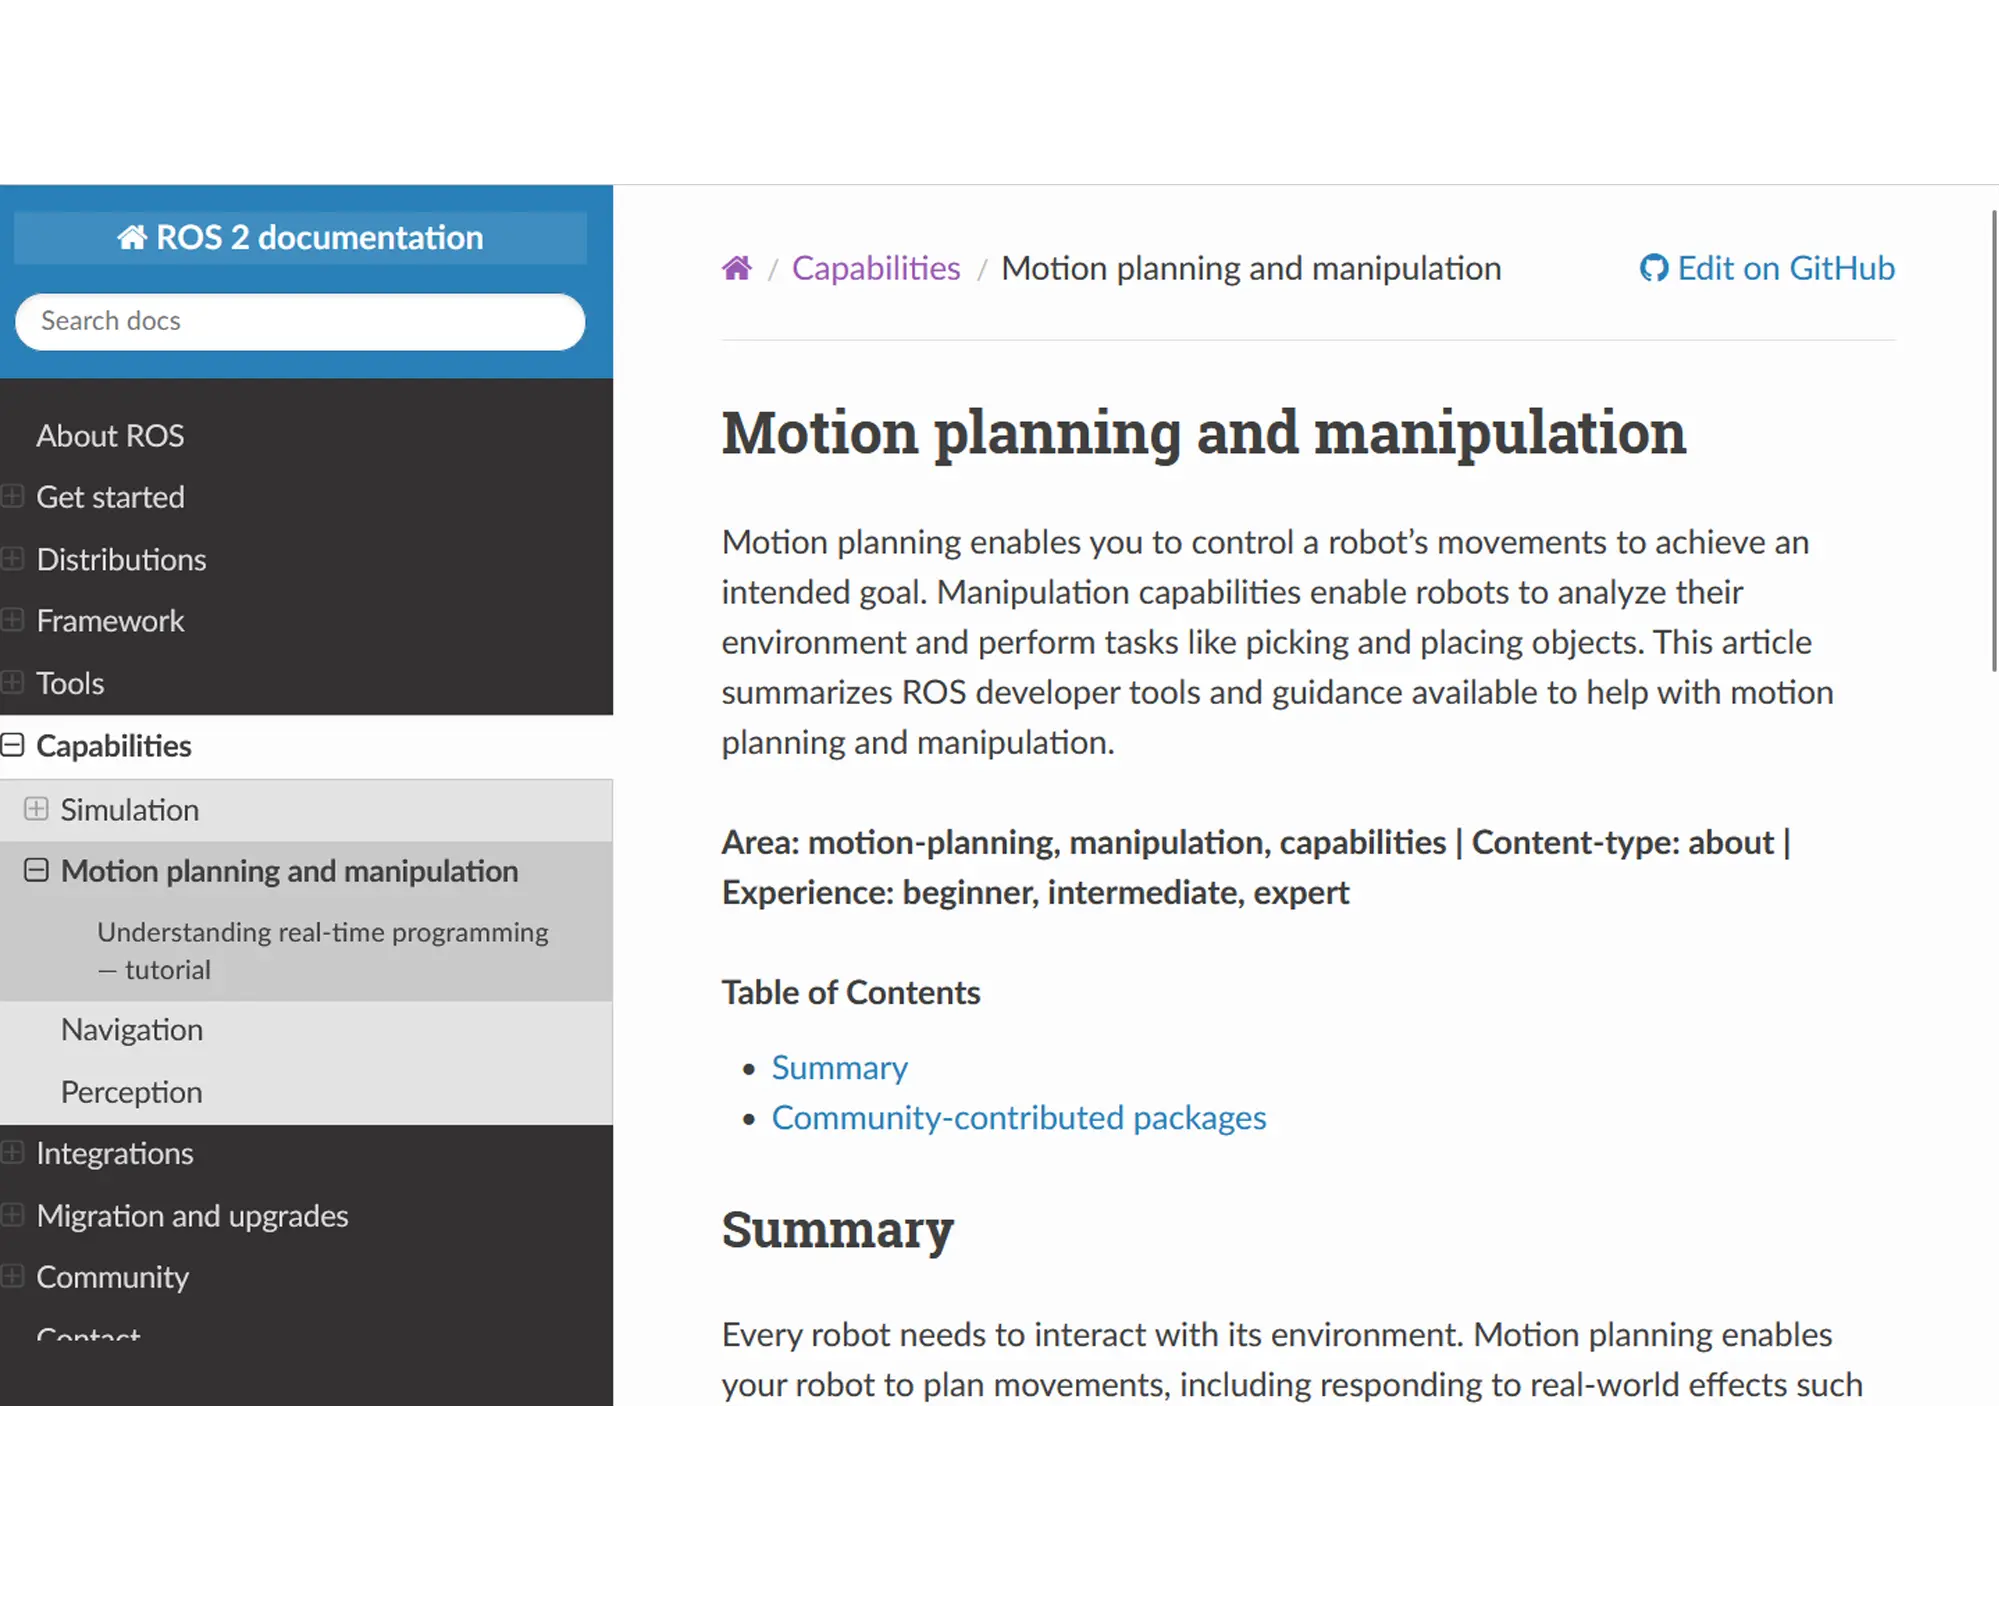
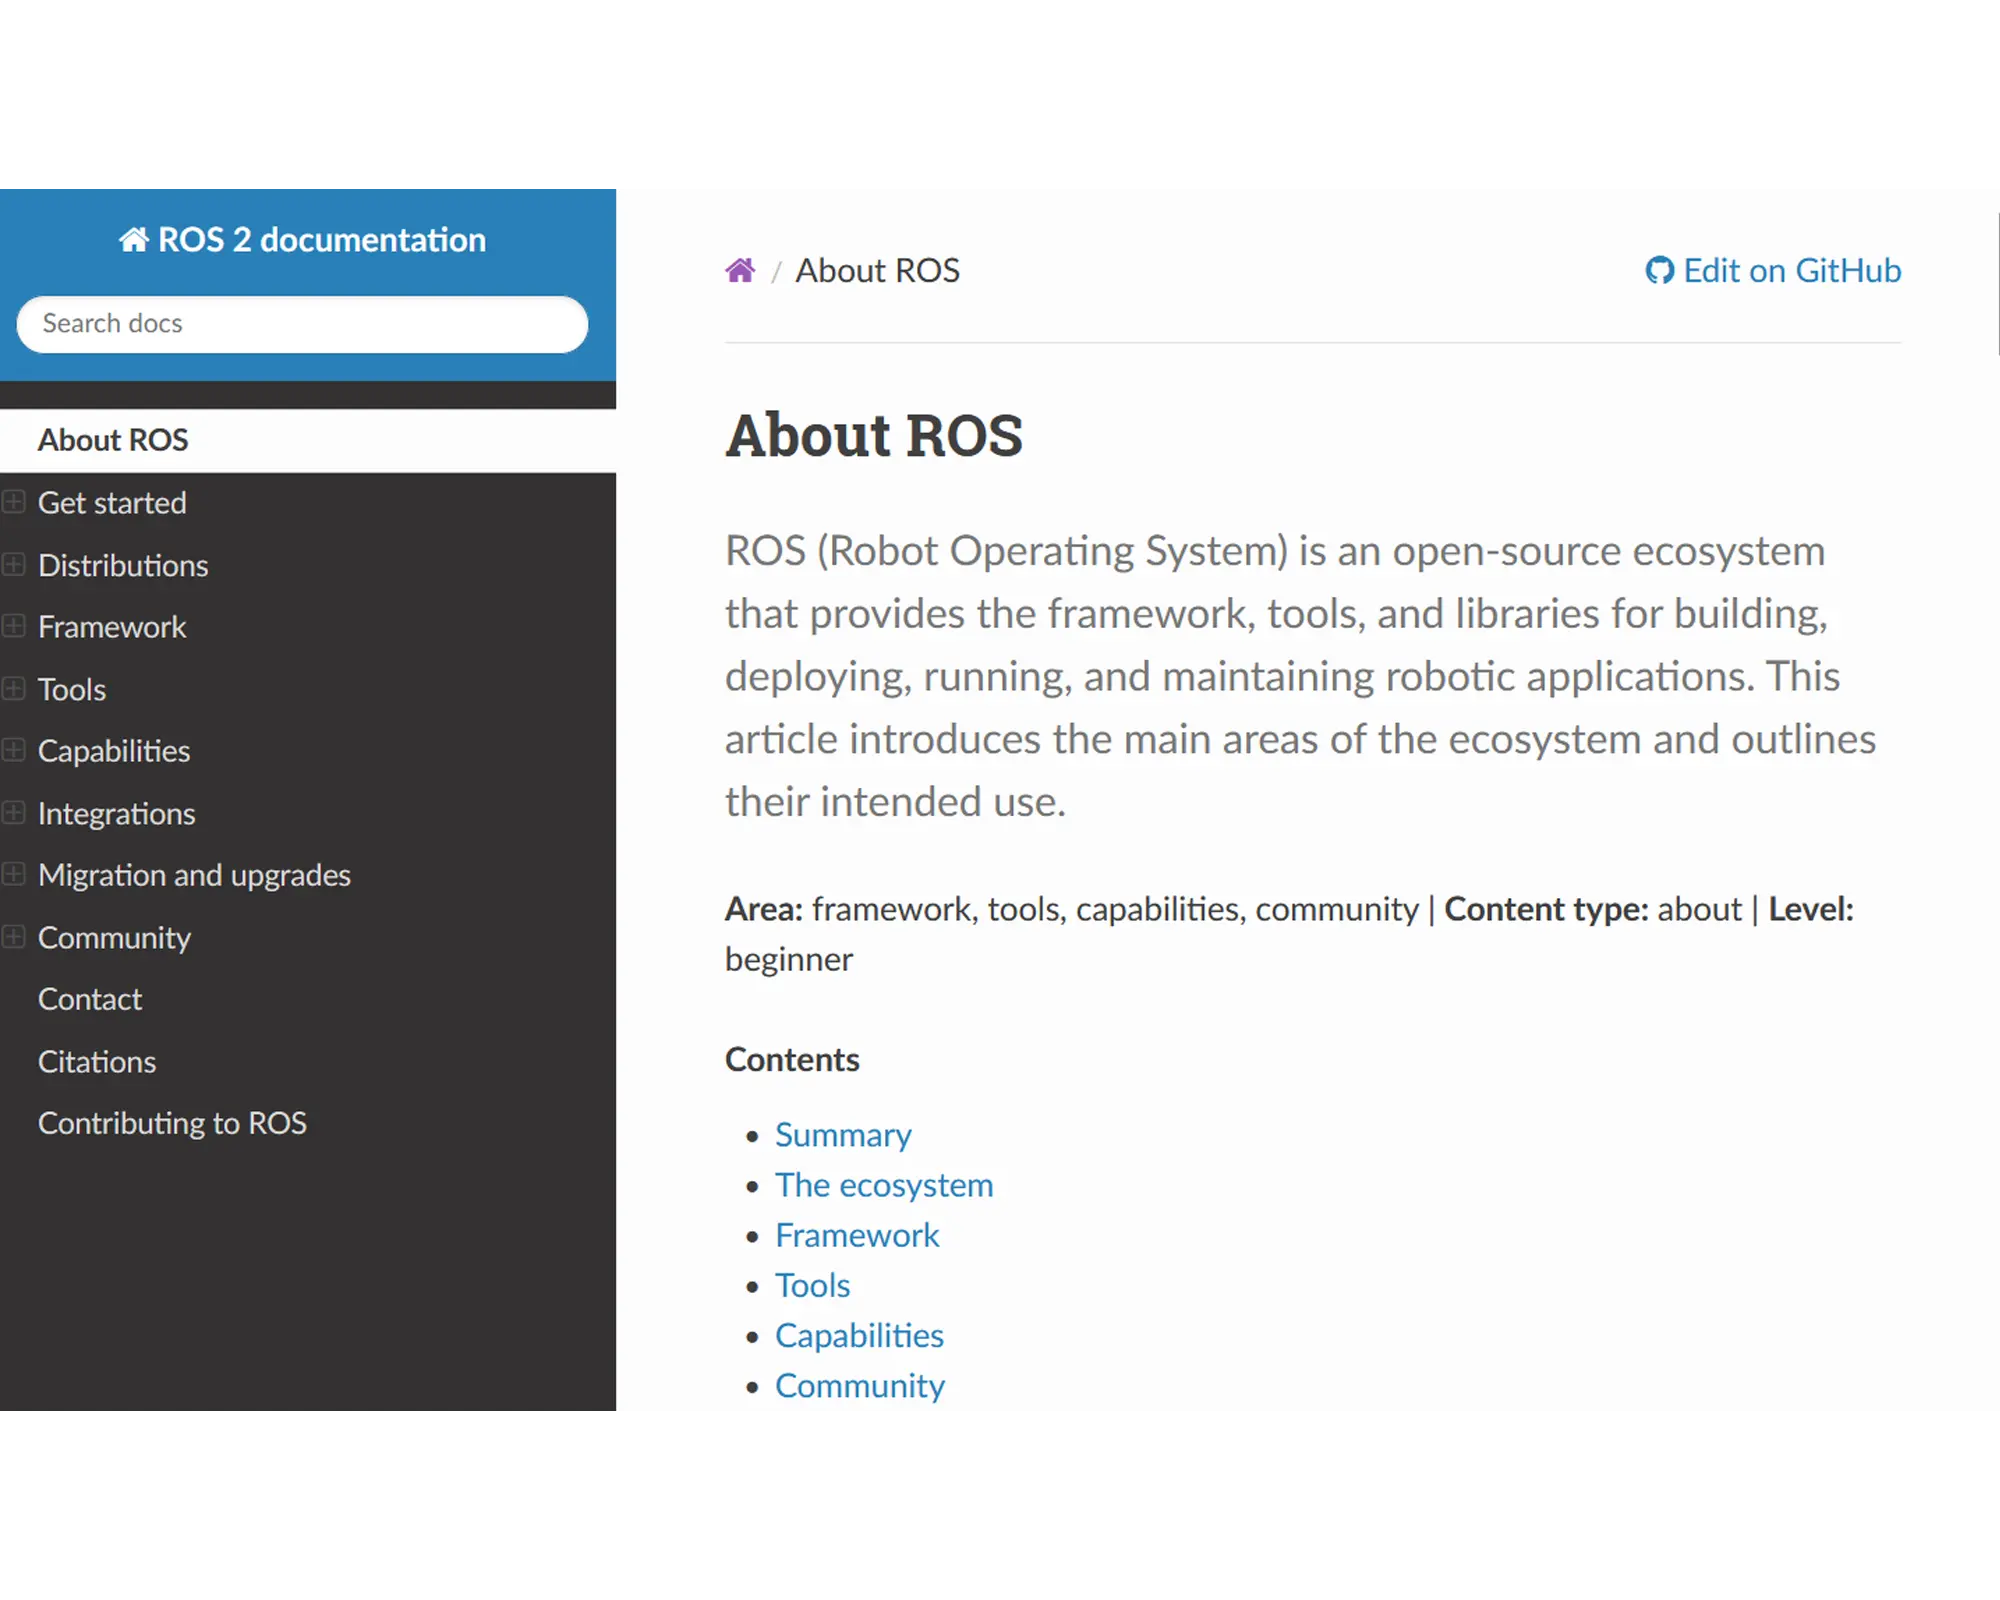
Pages of content we updated in the Open Robotics ROS (Robot Operating System) documentation site.
The impact
- Easier to find and use information on the site
- AI-ready content
- Improved information for learners and new users
What was the context for 3di helping Open Robotics?
Open Robotics manage ROS (Robot Operating System), which is an open-source ecosystem that provides the framework, tools, and libraries for building, deploying, running, and maintaining robotic applications. Over time, ROS has evolved from being a highly specialised framework – used by the same experts who develop it – to being widely used across a range of robotics applications. The documentation site didn’t keep up.
While the site contained a lot of detailed information, it wasn’t really working successfully for any of its audiences: there wasn’t enough context for anyone new to ROS to make use of the information available and apply it to achieve their goals, and the detailed how-tos and demos were hard to find. Maintaining the site was hard, resulting in inconsistency and duplication. Even the expert users were frustrated by knowing the piece of information they needed was available somewhere, but not being able to find it. Feedback from the community was that the documentation just wasn’t good enough.
On top of this, like other organisations, Open Robotics needed to ensure that all this information is suitable for consumption by AI tools too, to help people find out about the system and to support with developing ROS code.
The challenges Open Robotics faced
Open Robotics faced a unique combination of challenges:
ROS has a wide range of users, from complete beginners to seasoned experts. The documentation needs to support retrieval of relevant information by all – whether by AI, search engines or browsing the table of contents.
The open source context meant that any defined improvement patterns needed to be easy for people who aren’t professional technical authors to apply too.
A large body of documentation already existed, and a complete overhaul wasn’t going to be possible within the available budget. So the plan 3di developed needed to improve findability for all the existing documentation, while also setting out best practice for future documentation.
Lastly, ROS documentation uses the same build environment as the ROS code. After some consideration, we agreed together that it would be best to continue with this tooling, rather than switching to a new content tool. This meant developing some improvements to support better information retrieval.
The solution 3di created for Open Robotics
The 3di team made the following improvements:
- New content types – To best support information retrieval by both humans and machines, we defined suitable content types, each with a clear purpose and scope.
- Improved site structure – The original site included articles that contained good information, but often dived quickly into a low level of detail without putting the information into clear enough context for beginners to understand. One of the first pieces of work we did was to reorganise the articles around functionality. We created a way of describing ROS that everyone agreed on – essentially, defining a set of high-level features and capabilities which content can be organised around.
- Improved article content – Within each article, we added features to enable improved findability and information retrieval, such as metadata, predictable structure, and clear headings.
- Improved search and linking – Upcoming tooling developments will add a better search experience and automated linking between articles and the code packages that implement functionality.
- Content for learners – We created new content to support the new architecture, with a focus on articles to ensure ROS beginners can quickly become familiar with fundamental functionality, concepts and tools.
The results of the collaboration between 3di and Open Robotics
The combination of improvements 3di designed will promote improved findability and information retrieval – by humans and machines – addressing the issues raised by the ROS community and applying best practices to prepare the site for the future. This will help ensure ROS remains at the heart of robotics development by making it easier for everyone to learn and use the framework and tools it offers.
Open Robotics CTO Geoff Biggs published this blog post about the ROS Information Architecture redesign, and how it has helped Open Robotics here.